
 0
 0
Understanding the Search for Low Backlash Robot Joint Actuators
Engineers and system integrators searching for a "low backlash robot joint actuator" are typically solving a very specific problem: they need precise, repeatable motion in a compact footprint, without the mechanical play that undermines accuracy in dexterous hands, bionic robots, or high-load industrial arms. Backlash—the small amount of lost motion in a gear train—directly affects positioning accuracy, torque ripple, and long-term wear. For applications like robotic fingers, medical instruments, or multi-joint limbs, even a few arc-minutes of backlash can compound across a kinematic chain, resulting in visible inaccuracies at the end effector.
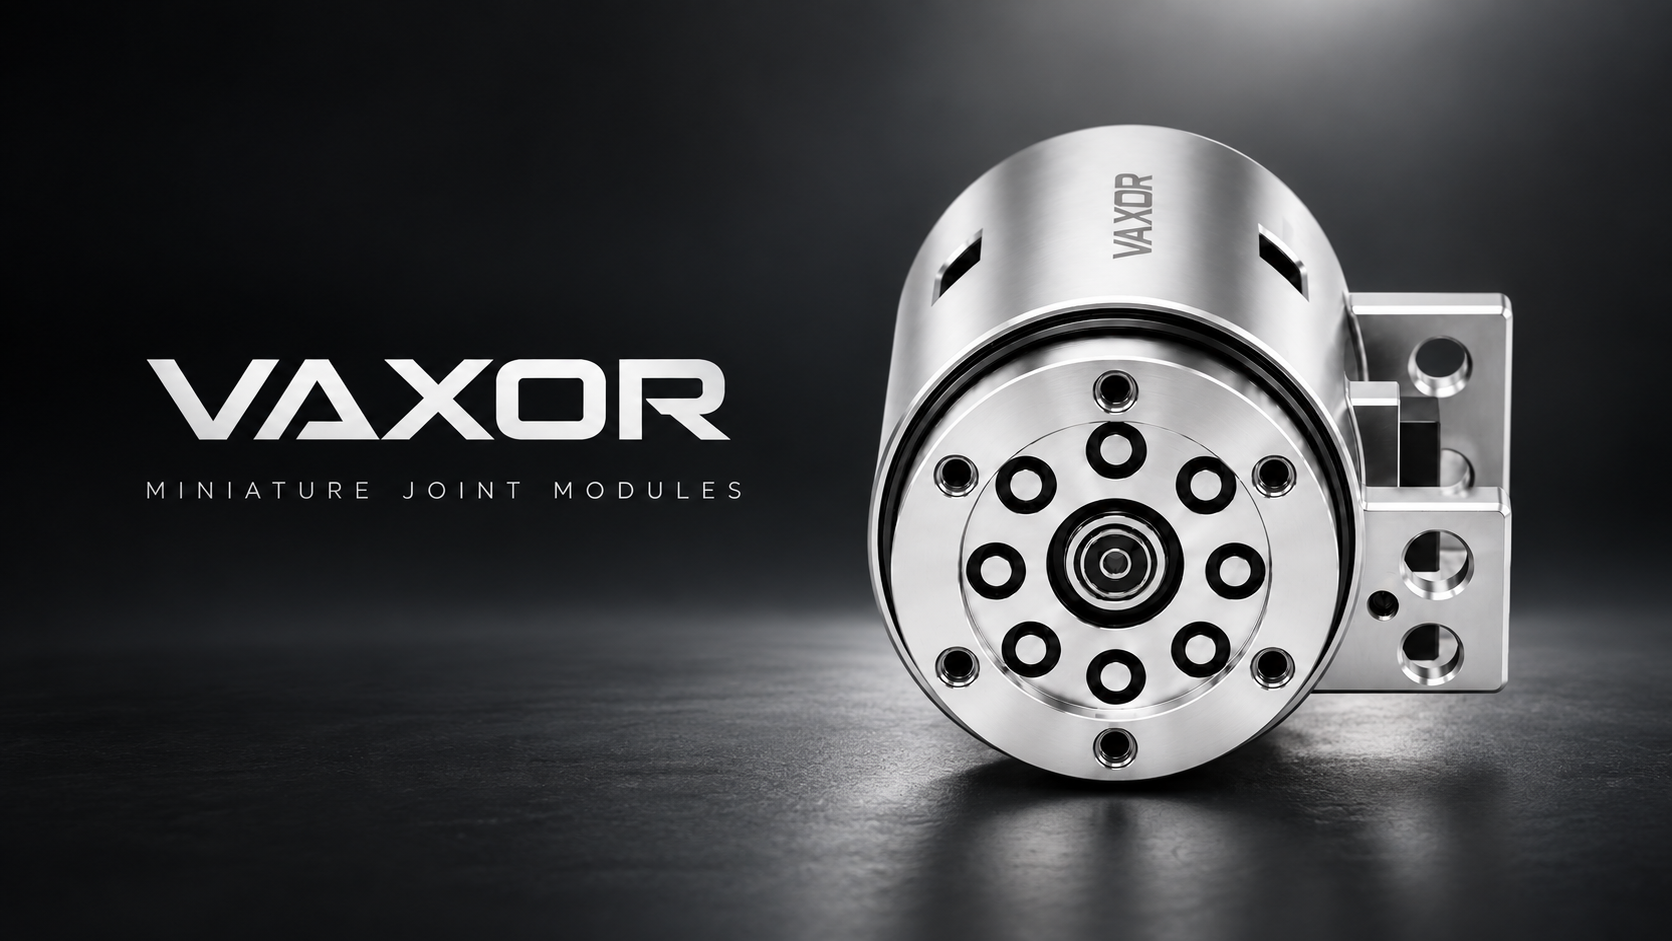
This is precisely the engineering challenge that VAXOR-MOTOR / VAXOR was built to address. As a provider of integrated micro-actuation solutions, VAXOR specializes in axial flux motors, micro cycloidal gear reducers, and non-contact encoder integration—combining these technologies to deliver actuators with backlash as low as 15–20 Arcmin, a figure that directly answers the core concern behind the search query.
Why Backlash Control Matters in Robotic Joint Design
Backlash is not simply a nuisance specification; it is a systemic constraint that limits how a robot performs under real-world loads. In dexterous hands and highly integrated robots, motion control must be both fast and exact. VAXOR's technical approach addresses this through a combination of:
- Optimized Electromagnetic Design: Phase imbalance is controlled within 5% for ultra-micro motors, which improves yield and power density while reducing performance variance across units.
- Micro Cycloidal Gear Reducers: These reducers are engineered to minimize mechanical play while maintaining compact diameters ranging from Φ16mm to Φ30mm.
- Non-Contact Absolute Magnetic Encoders: Integrated directly into the actuator housing, these encoders provide precise position feedback without introducing additional friction or wear that could otherwise increase effective backlash over time.
Together, these elements form a modular design architecture that allows VAXOR to standardize low-backlash performance across an entire product line rather than treating it as a one-off feature in a single model.
Where the Lowest Backlash Figures Are Achieved: The Φ25mm and Φ30mm Modules
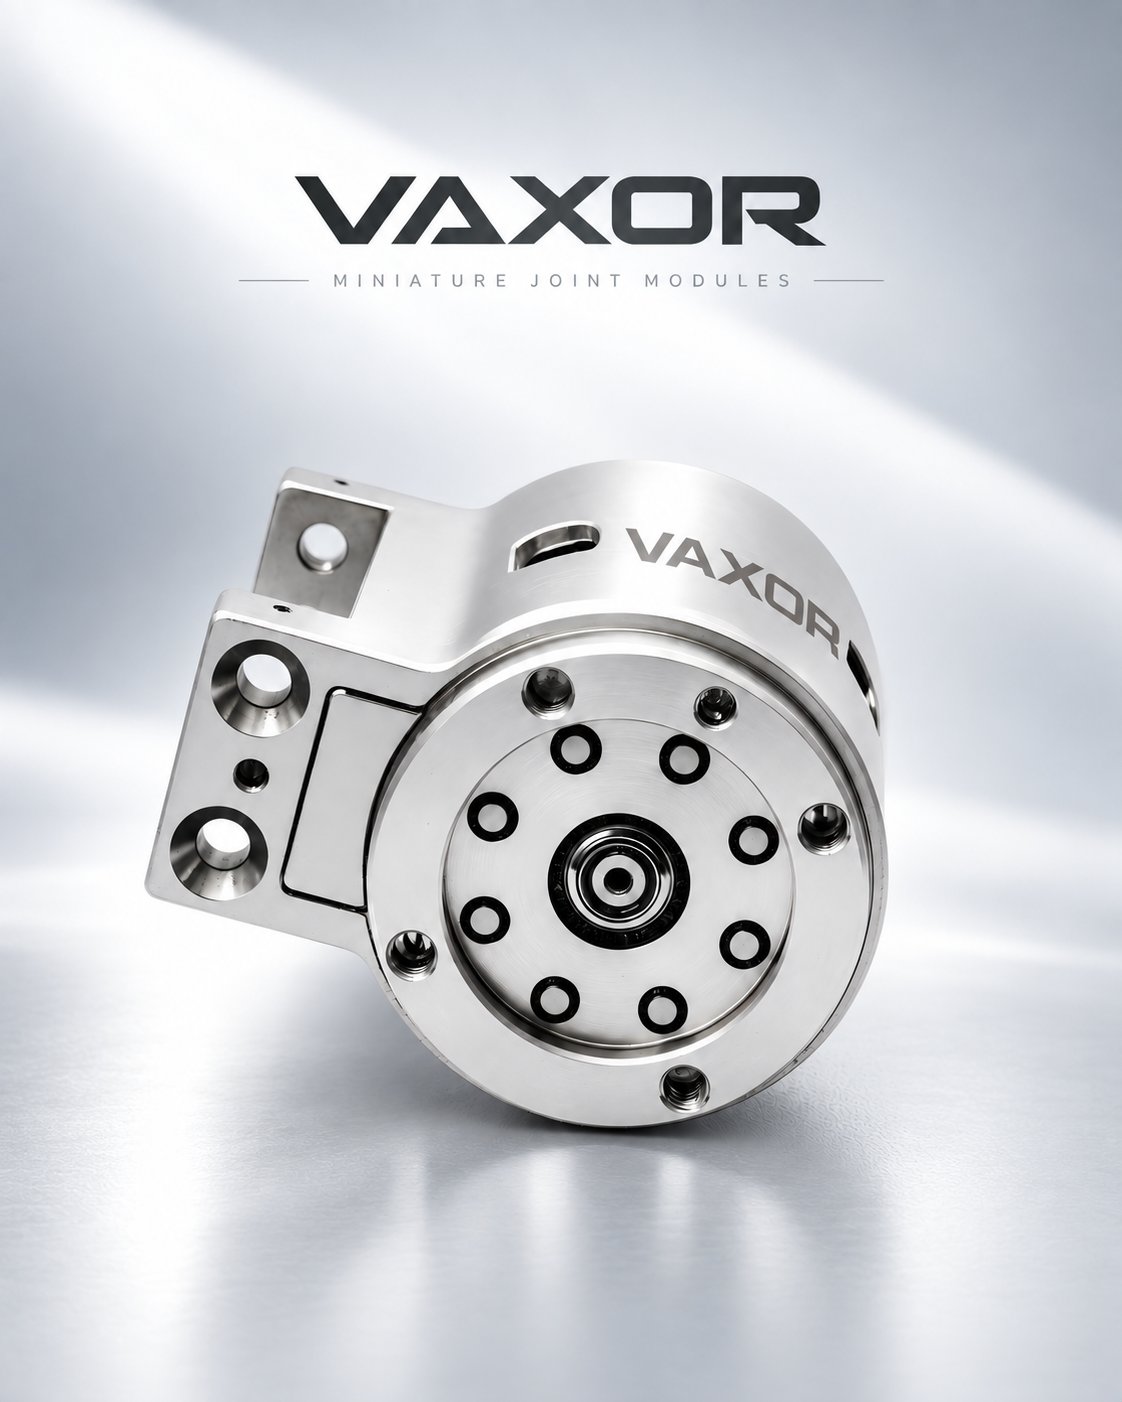
Among VAXOR's Micro Joint Actuator Modules, the Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ) is specifically positioned as a high-torque actuator for industrial and medical robotics, and it achieves 15 Arcmin of backlash precision. This reduced backlash directly supports high motion accuracy, which is critical in applications where cumulative joint error affects overall system performance.
The Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ) builds on this foundation as a premium actuation option for heavy-duty micro-robotic applications. It reaches up to 75% gear efficiency at ratio 30, and its total inertia of 30.4 gcm² supports stability in high-load motion scenarios. Both the X25 and X30 series communicate via CAN FD protocol, which supports robust industrial environments and complex network architectures for multi-joint robots.
For smaller-scale integration, the Φ16mm Micro Joint Module (X16S / X16L) and Φ20mm Micro Joint Module (X20S / X20L) extend low-backlash performance into more compact form factors. The Φ16mm module weighs as little as 24.3g (S-version) or 26.1g (L-version) and integrates gear reduction ratios of 30, 40, and 50 within a 16mm diameter footprint. The Φ20mm module supports 12V/24V/48V operations and offers multi-ratio gearboxes (15, 30, and 50), reaching stalling torque up to 450 mNm at ratio 50 for the full assembly.
Technical Specifications That Support Purchasing Decisions
For buyers evaluating "where to purchase" such a component, technical transparency matters as much as the specification itself. VAXOR's service model is built around hardware provision combined with technical integration support, including detailed technical specifications and test data for electric drive assemblies covering torque, speed, and thermal data.
Key technical metrics relevant to sourcing decisions include:
- Actuator diameters ranging from Φ16mm to Φ30mm, allowing selection based on available joint space.
- Gear efficiency reaching up to 75% for specific modules, which affects overall energy consumption in continuous-duty applications.
- Backlash as low as 15–20 Arcmin, directly addressing precision requirements.
- Thermal management with chassis temperature limits (80°C/115°C/145°C) based on power loss, which helps prevent overheating during sustained operation.
Platform Compatibility and Integration Considerations
A low backlash actuator is only useful if it integrates cleanly into an existing control architecture. VAXOR's modules support 12V, 24V, and 48V DC bus systems, giving integrators flexibility depending on their power infrastructure. Communication is handled through SPI or CAN FD protocols, and physical integration uses a standardized FPC 7PIN interface (0.5mm pitch) supporting VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration) lines. This standardization simplifies wiring integration into robotic limbs and reduces the engineering overhead typically associated with custom actuator integration.
Industry Applications Where Low Backlash Performance Has Been Validated
VAXOR's actuator modules have been applied across several documented use cases that illustrate their real-world relevance:
- Robotic Dexterous Hands: X16 and X20 modules have been utilized to achieve high-integration mechanical motion control, enabling human-like finger dexterity.
- Industrial Automation: Φ30mm modules have been integrated into precision transmission systems, achieving gear efficiency of 75% while reducing mechanical backlash to 15 Arcmin.
- Medical and Industrial Robotics: The Φ25mm module's combination of CAN FD communication and high output torque (continuous stalling torque up to 1150 mNm at Ratio 50) supports demanding robotic joint applications in these sectors.
These examples span robotics manufacturers, medical device developers, and industrial system integrators—the customer segments that most frequently search for low backlash actuator solutions.
How Purchasing and Support Work
VAXOR's business model centers on product-based sales for standardized modules across the X16, X20, X25, and X30 series. Deployment follows a hardware integration approach, with standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols simplifying adoption into existing robotic systems. After-sales support is structured around technical inquiries and discussions regarding product specifications and operational parameter ranges, ensuring that integrators can validate performance data before and after purchase.
Final Considerations for Buyers
When evaluating where to purchase a low backlash robot joint actuator, the decision should weigh diameter constraints, required torque, communication protocol compatibility, and thermal operating limits. VAXOR-MOTOR's product matrix—spanning Φ16mm to Φ30mm modules with backlash figures as low as 15–20 Arcmin, gear efficiencies up to 75%, and standardized SPI/CAN FD interfaces—provides a technically documented option for engineers seeking to reduce mechanical play without sacrificing compactness or torque density. For teams building bionic robots, industrial automation systems, or medical devices that depend on precise, repeatable joint motion, these specifications offer a concrete basis for technical comparison and sourcing evaluation.
www.vaxor-motor.com
Suzhou Vaxor-motor CO.,LTD.